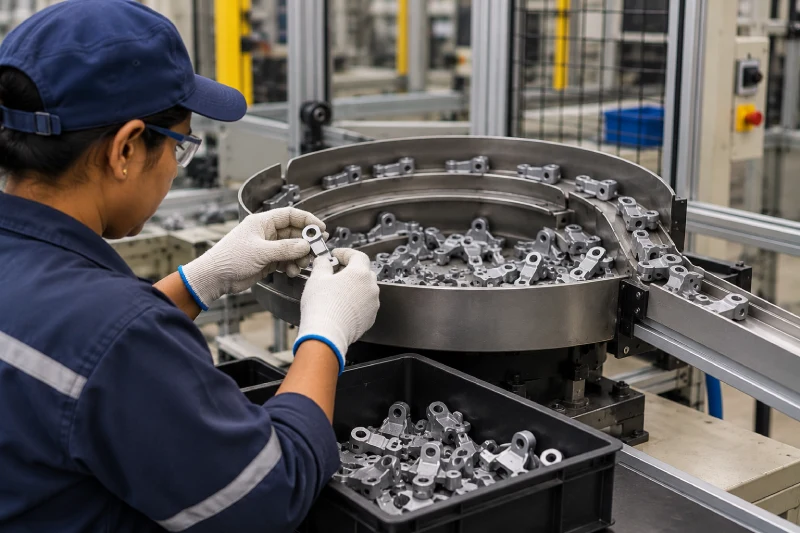
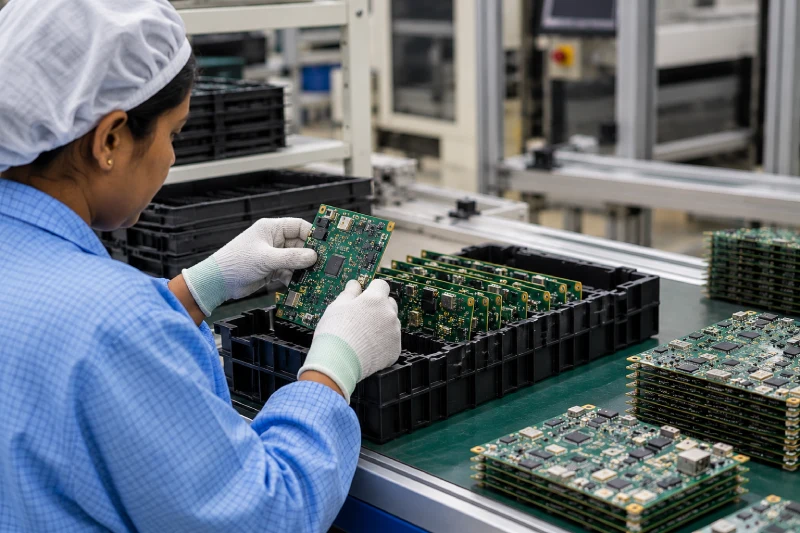
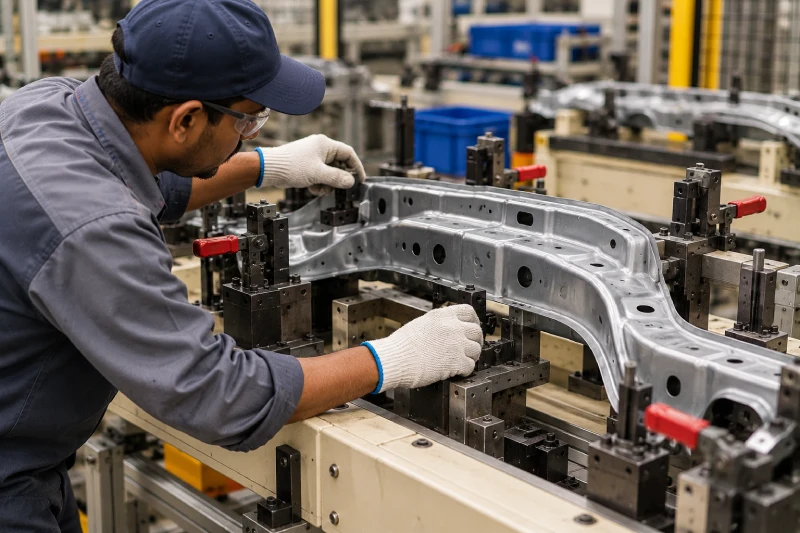
Fixtures, bowl feeders, and hard stops add cost and limit flexibility. If parts arrive in slightly different positions, a blind robot misses, jams, or damages them.
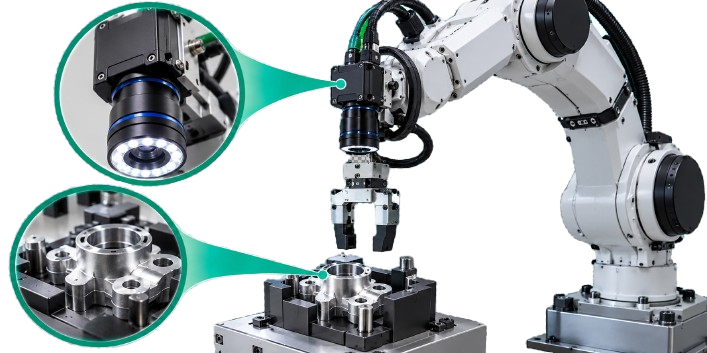
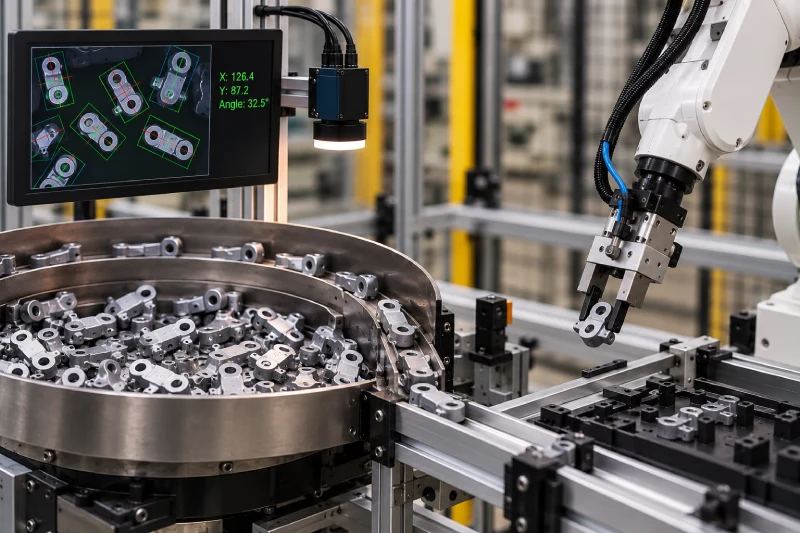
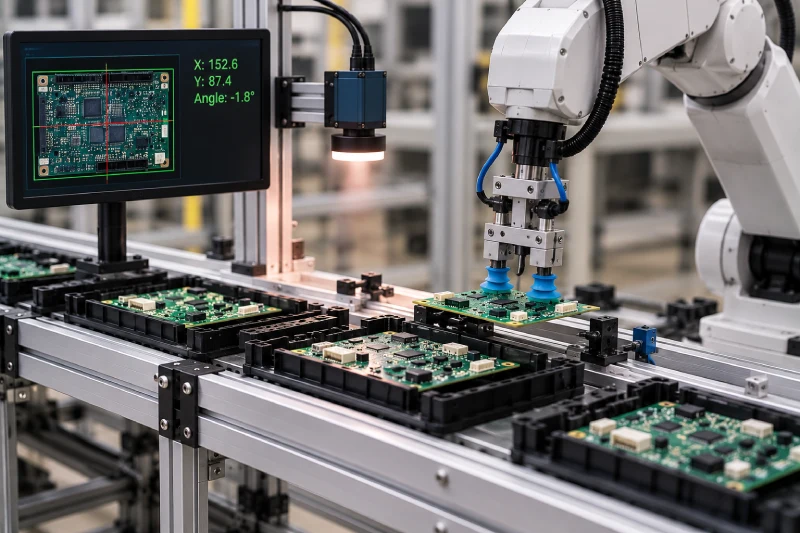
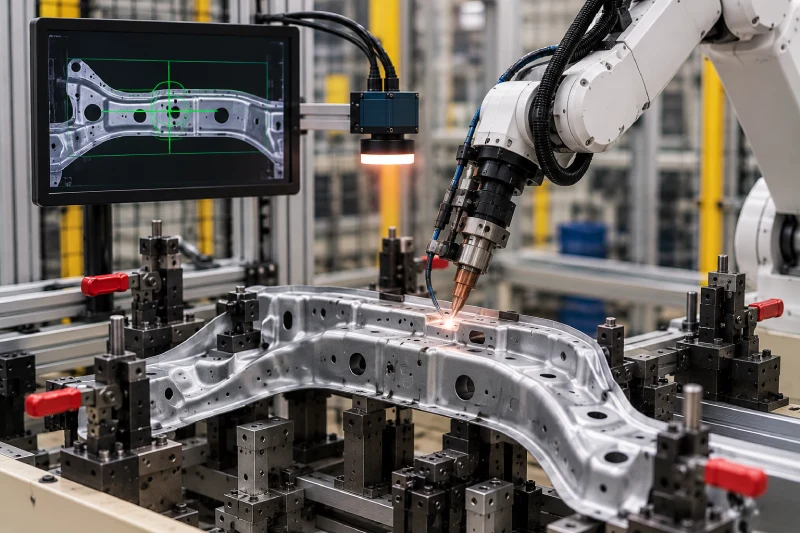
A camera finds each part, calculates its position and angle, and passes corrected coordinates to the robot in milliseconds. The same view can inspect the part, so one station both guides and verifies.